Personal prototype · Signal processing
My contribution
I built a Raspberry Pi audio-processing pipeline with an ESP32 display interface and tested it on engine recordings.
Personal prototype
Prototype tested on Tecnam P92 recordings; no tachometer ground truth, and 3 of 14 chunks (21%) of one recording pick the wrong engine order.
Problem
Estimating aircraft engine RPM and operational status in real time without dedicated tachometer hardware.
System
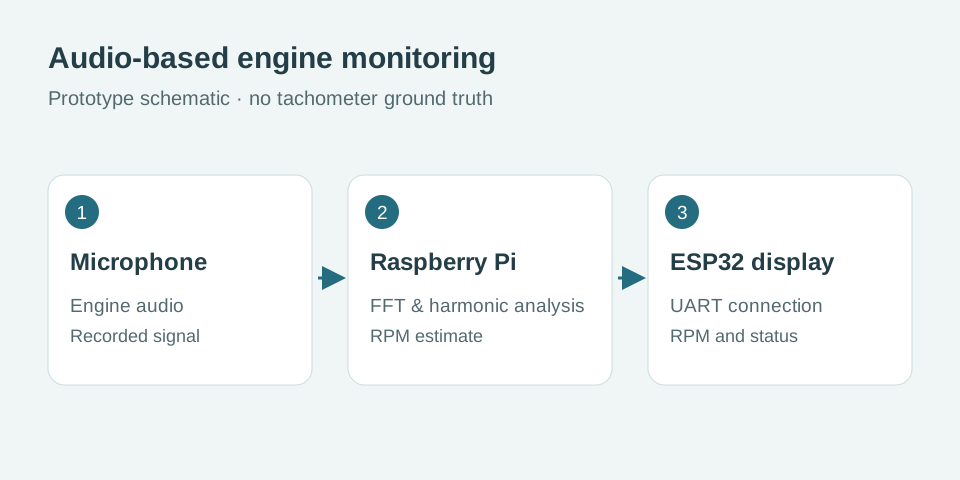
FFT-based signal processing runs on microphone audio on a Raspberry Pi, which transmits extracted RPM and status over UART to an ESP32 controller for real-time display.
Field testing
Tested on real audio recordings from a Tecnam P92 / Rotax 912 engine, giving plausible RPM values from the acoustic signal alone, cross-checked against the harmonic order structure. A personal research and prototyping project: not certified avionics equipment and not flight-safety validated.
Limitations
No tachometer reference was recorded, so RPM accuracy is not measured against ground truth. The peak picker can lock onto the wrong engine order: on the 1000 rpm recording, 3 of 14 five-second chunks (21%) report about 500 rpm instead of about 1000, as analysed in the project's technical documentation.